|
Youngjin Seo I'm an Integrated M.S./Ph.D. student and the student lab leader of the Robotics and Intelligent System Engineering Lab (RISE Lab) at Sungkyunkwan University (SKKU), advised by Prof. Hyungpil Moon. I'm interested in robot learning for manipulation, with a focus on imitation learning, vision-language-action (VLA) models, and force-based policies. |
|
Education
|
Publications |
|
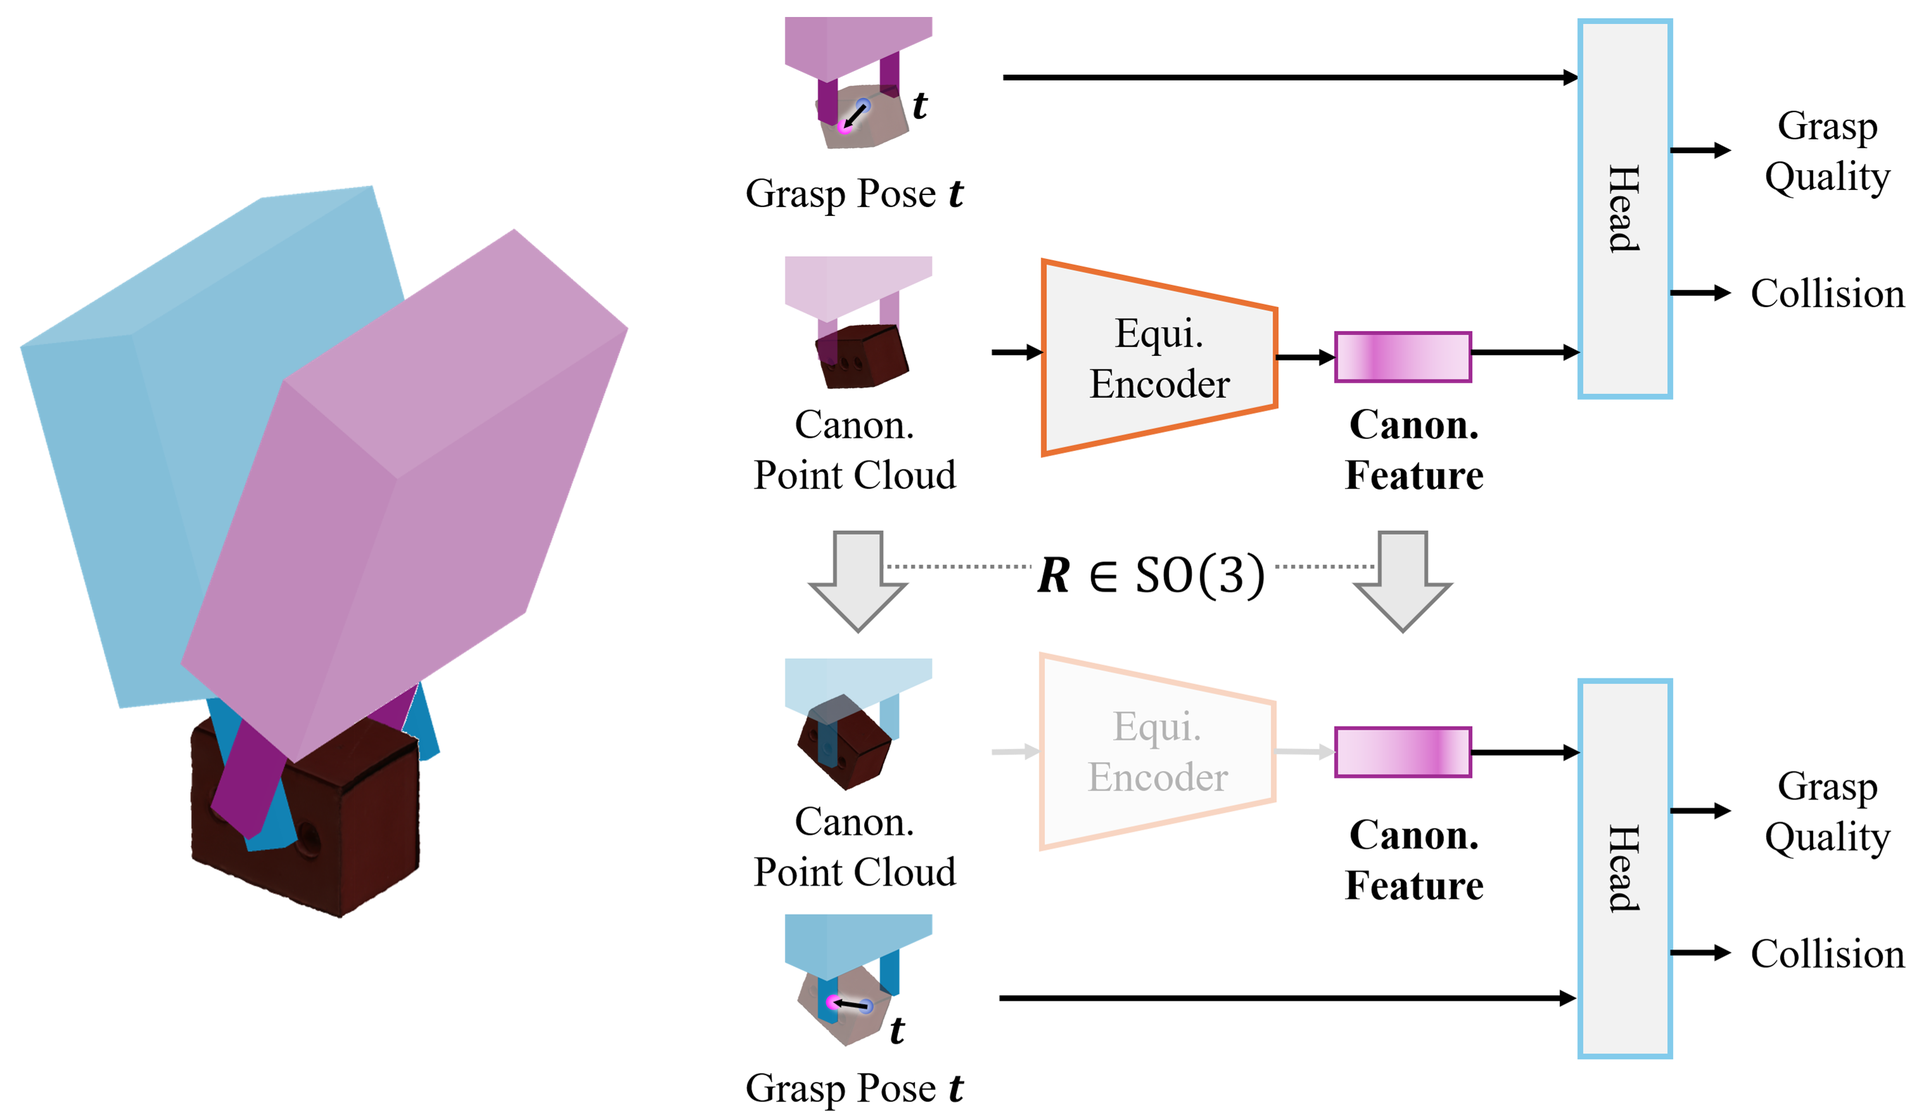
EquiGQNet: Fast Grasp Quality Evaluation via Shared Equivariant Point Cloud Encoding
Sungwon Seo, Jaeseog Won, Jiyou Shin, Youngjin Seo, Hyunjun Kim, Seokmin Yoon, Tuan Luong, Hyungpil Moon arXiv, 2026 project page / arXiv A 6-DoF grasp quality evaluator that replaces per-candidate re-encoding with an SO(3)-equivariant encode-once-then-rotate scheme, reusing a shared scene encoding while keeping grasp-relative local geometry. |
|
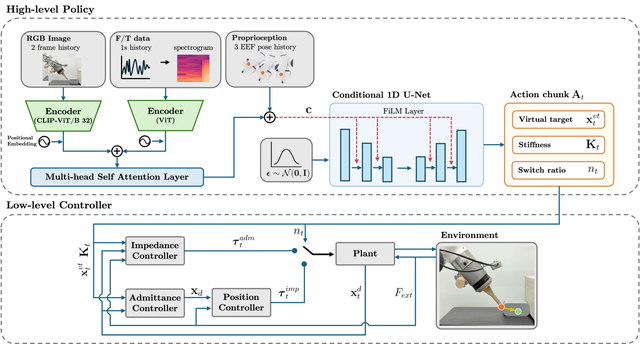
URF: A Unified Robot Control-Policy Framework for Stable Contact Aware Manipulation
Jiyou Shin, Youngjin Seo, Jaeseog Won, Sungwon Seo, Hyunjun Kim, Seokmin Yoon, Tuan Luong, Hyungpil Moon arXiv, 2026 project page / arXiv A manipulation policy that predicts not only a compliant action but also the controller behavior used to execute it, jointly outputting a virtual target, a stiffness matrix, and an impedance-admittance switch ratio. |
|
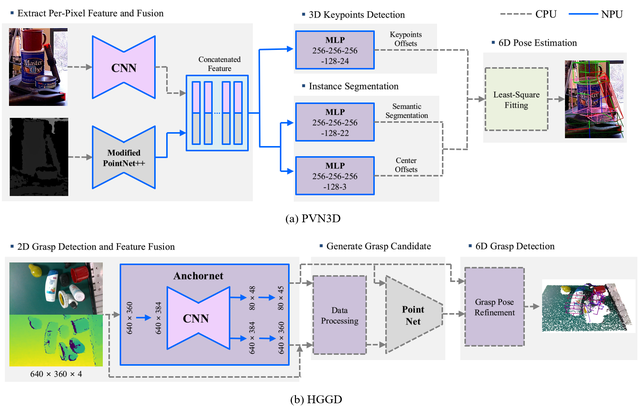
Benchmarking 6D Pose Estimation and 6-DoF Grasp Detection on a Low-Power NPU: Case Studies with PVN3D and HGGD
Youngjin Seo*, Hyojun Yun*, Hong-ryul Jung, Hyungpil Moon (* equal contribution) International Conference on Control, Automation and Systems (ICCAS), 2025 paper A benchmark of PVN3D and HGGD on a low-power NPU, measuring whether 6D pose estimation and 6-DoF grasp detection stay practical under embedded compute budgets. |
Projects |
|
Empowering Legged Robots with Multimodal Mapping and Localization for Industrial Environments
Aug. 2026 – present |
|
Development of a K-Logistics Humanoid Robot Integrated with a High-Sensitivity Robotic Hand Based on a Multimodal AI Foundation Model
Sep. 2025 – Sep. 2026 |
|
Development of a SLAM-Based Drone System for Cart Monitoring
Apr. 2026 – Aug. 2026
|
|
Development of Core Technology for Mobile Manipulator for 5G Edge-Based Transportation and Manipulation
Jun. 2025 – Dec. 2025
|
|
Development of Low-Cost, High-Performance Visual Sensor Technology Integrated with AI Semiconductors and AI Algorithms Designed for Robots
Dec. 2024 – Nov. 2025 |
|
Development of a Simulation Drone Competition Utilizing Realistic Environments and Drone Dynamics
Mar. 2023 – Dec. 2023
|
Teaching
|
|
Feel free to reach out at soh2879 [at] g.skku.edu for any questions. Template from Jon Barron's website. |